


Technology
System integrity, not a list of brands.
Control, motion, robotics, vision, safety and mechanics directly affect one another in a machine. We choose technology with that interaction in mind.
Our solutions are compatible with industry-standard PLC, servo and robot platforms; the platform is chosen to suit the customer's standard and the process requirement.
T-01 · CONTROL
Control
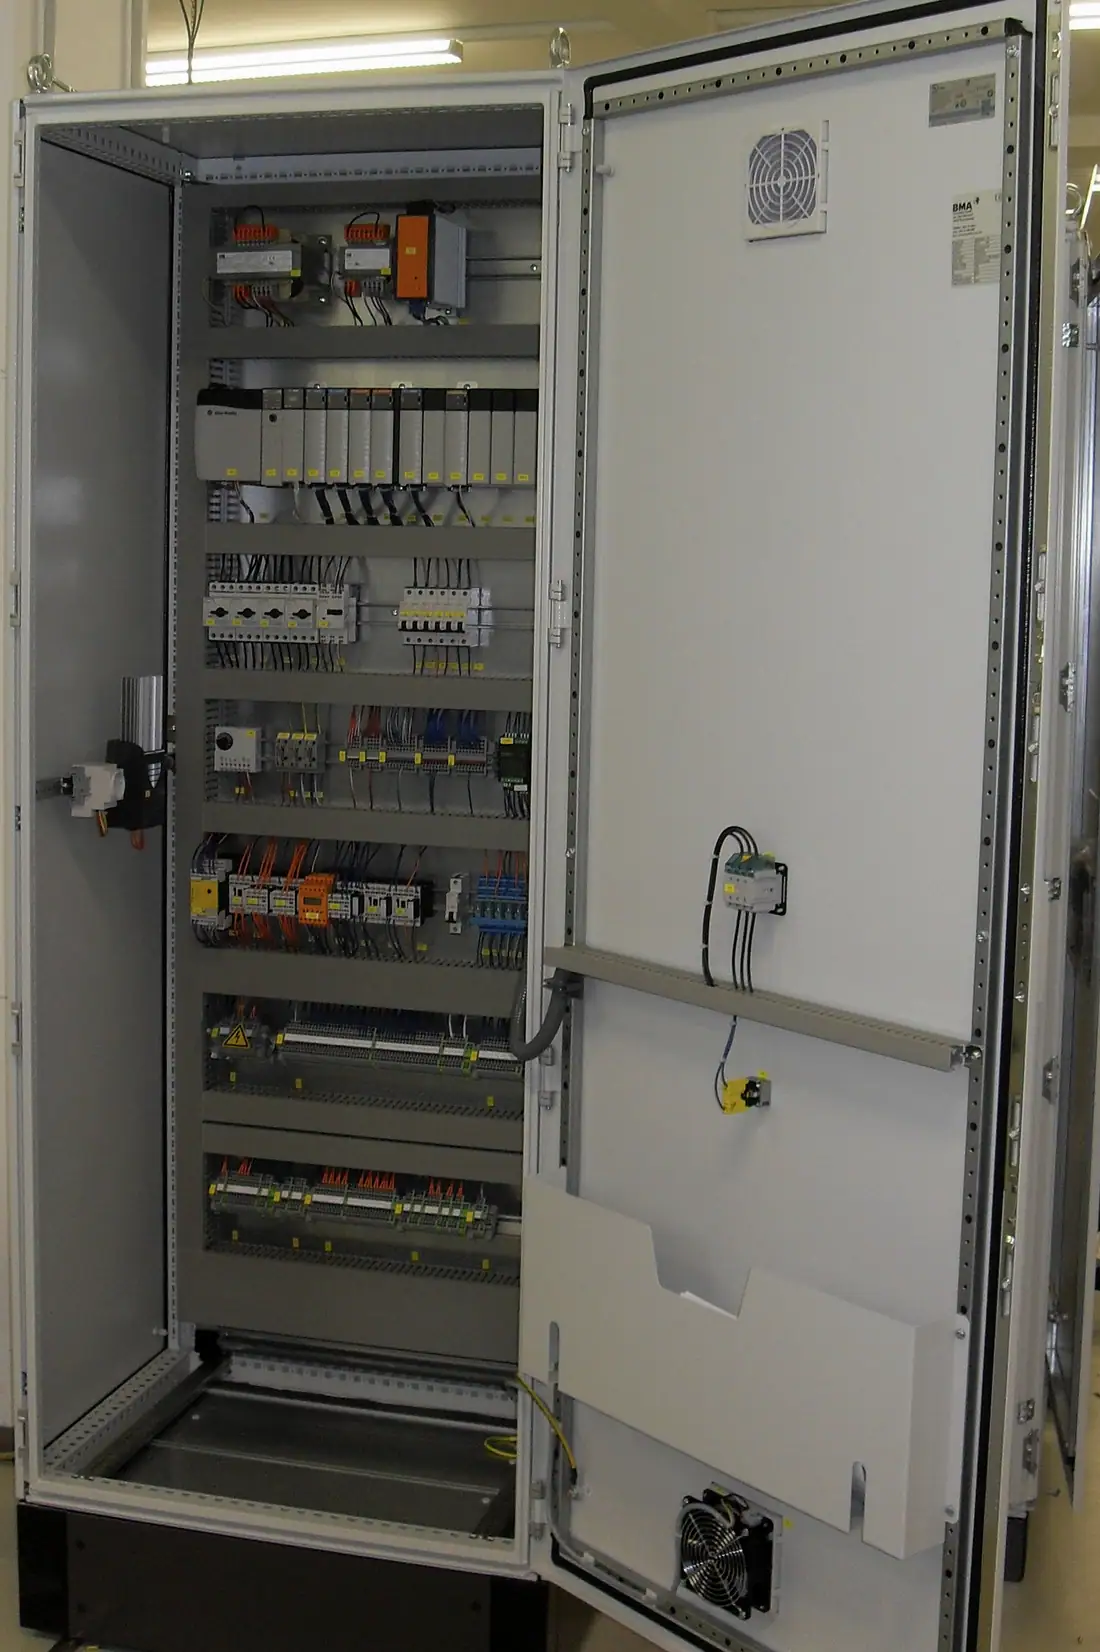
The control architecture determines how a machine behaves and how it will be maintained. We build software that is modular, readable and documented.
Approach
- Modular software structure compatible with industry-standard PLC platforms
- Recipe management, alarm history and fault diagnostic screens
- Distributed I/O and industrial fieldbus communication
- Open interfaces to host systems (MES / data acquisition)
T-02 · MOTION
Motion
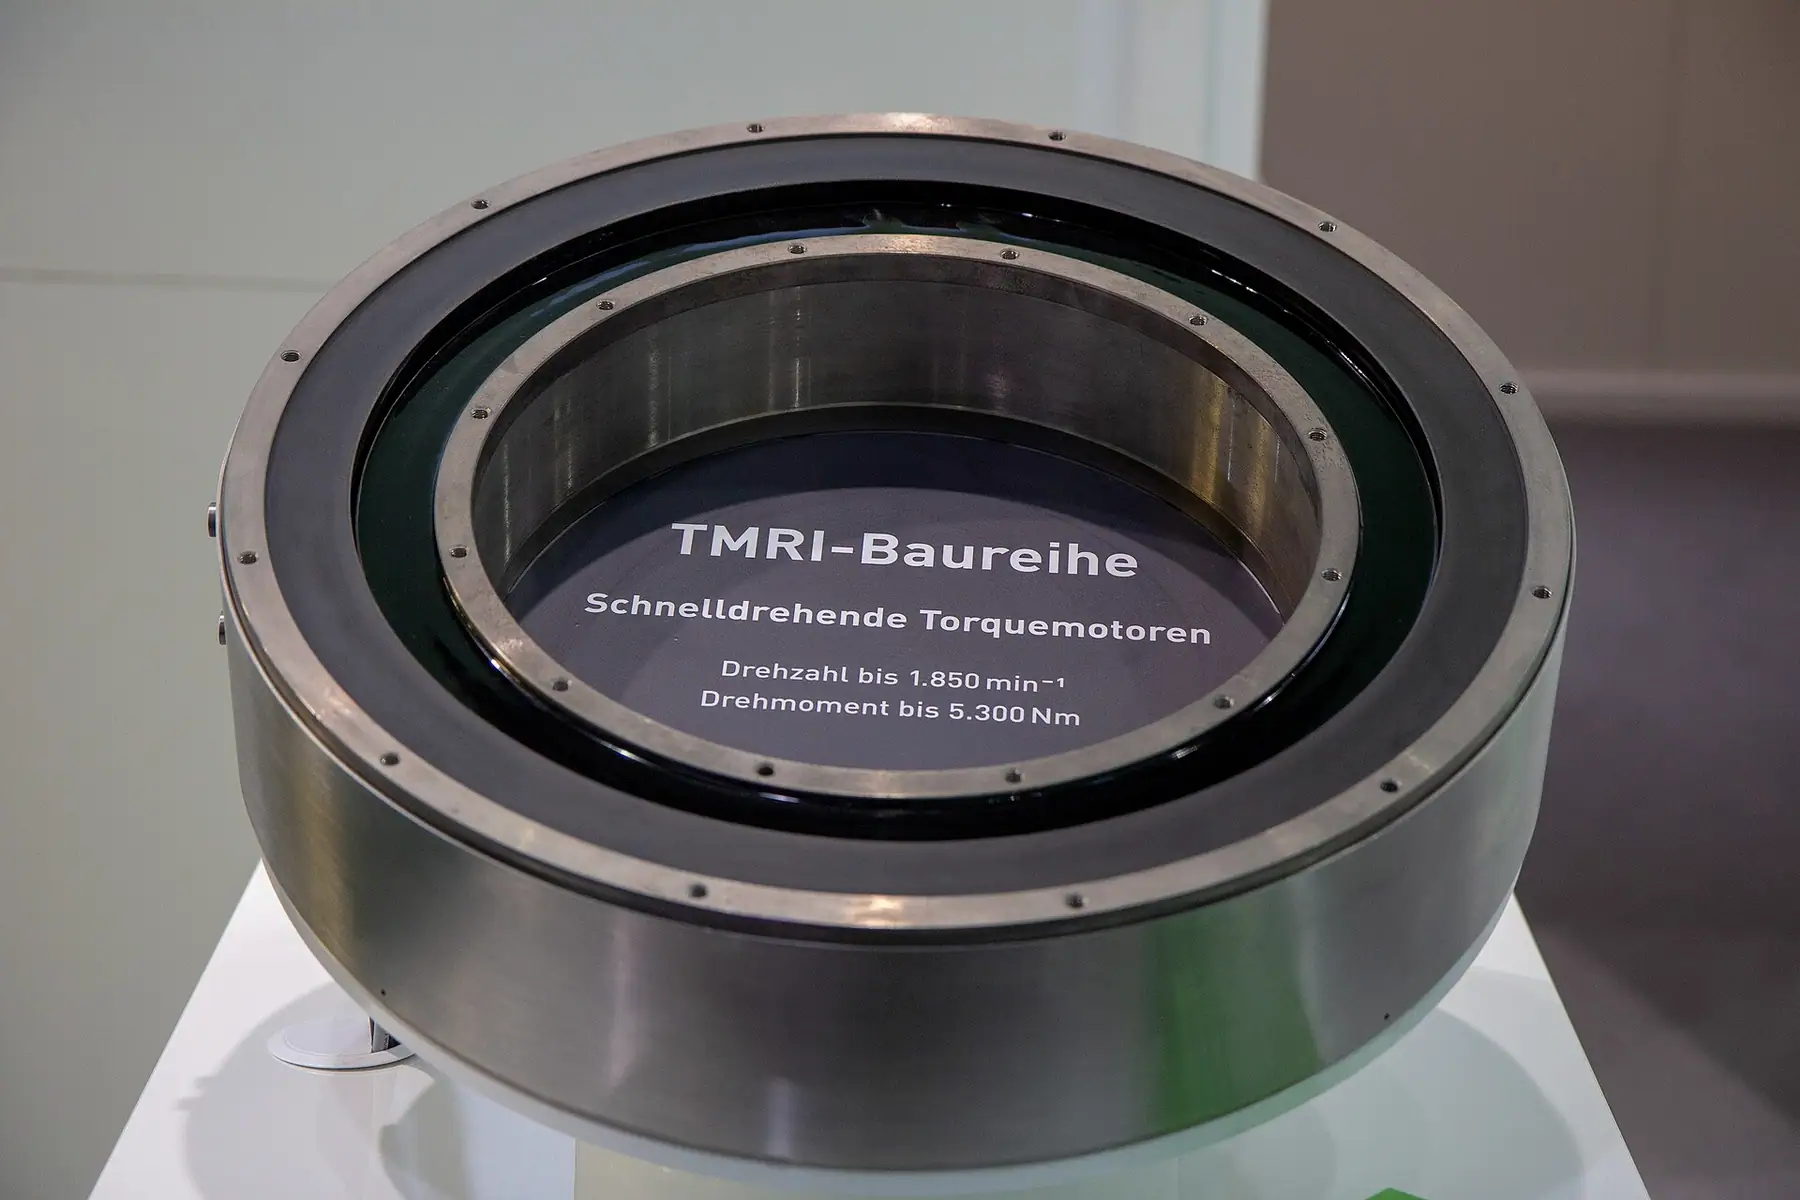
The right drive is chosen by calculating load, speed, precision and cycle profile together. Servo axes turn a mechanical adjustment into a software parameter.
Approach
- Motor and gearbox selection based on load and motion-profile calculations
- Servo axes with position, speed and torque control
- Synchronised axes and electronic cam applications
- Linear axis, ball screw and belt drive solutions
T-03 · ROBOTICS
Robotics
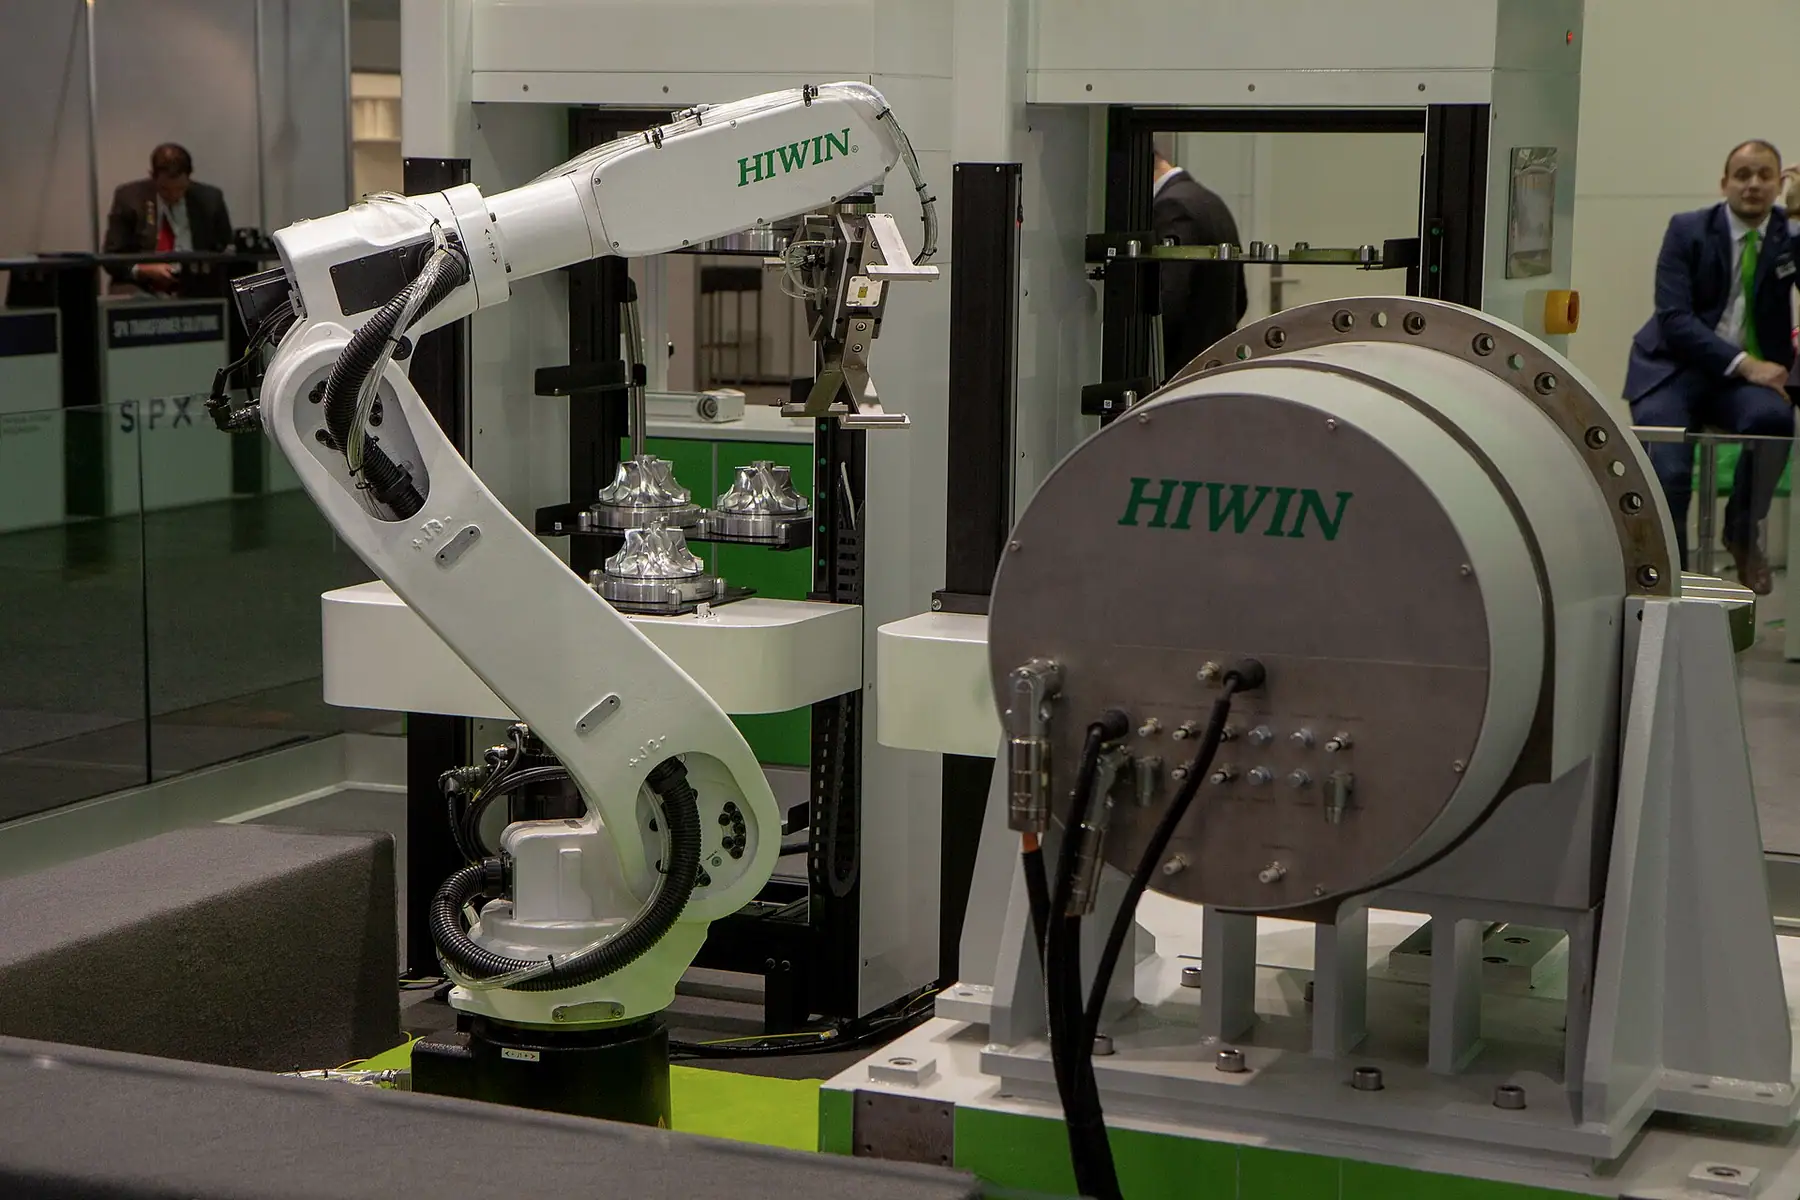
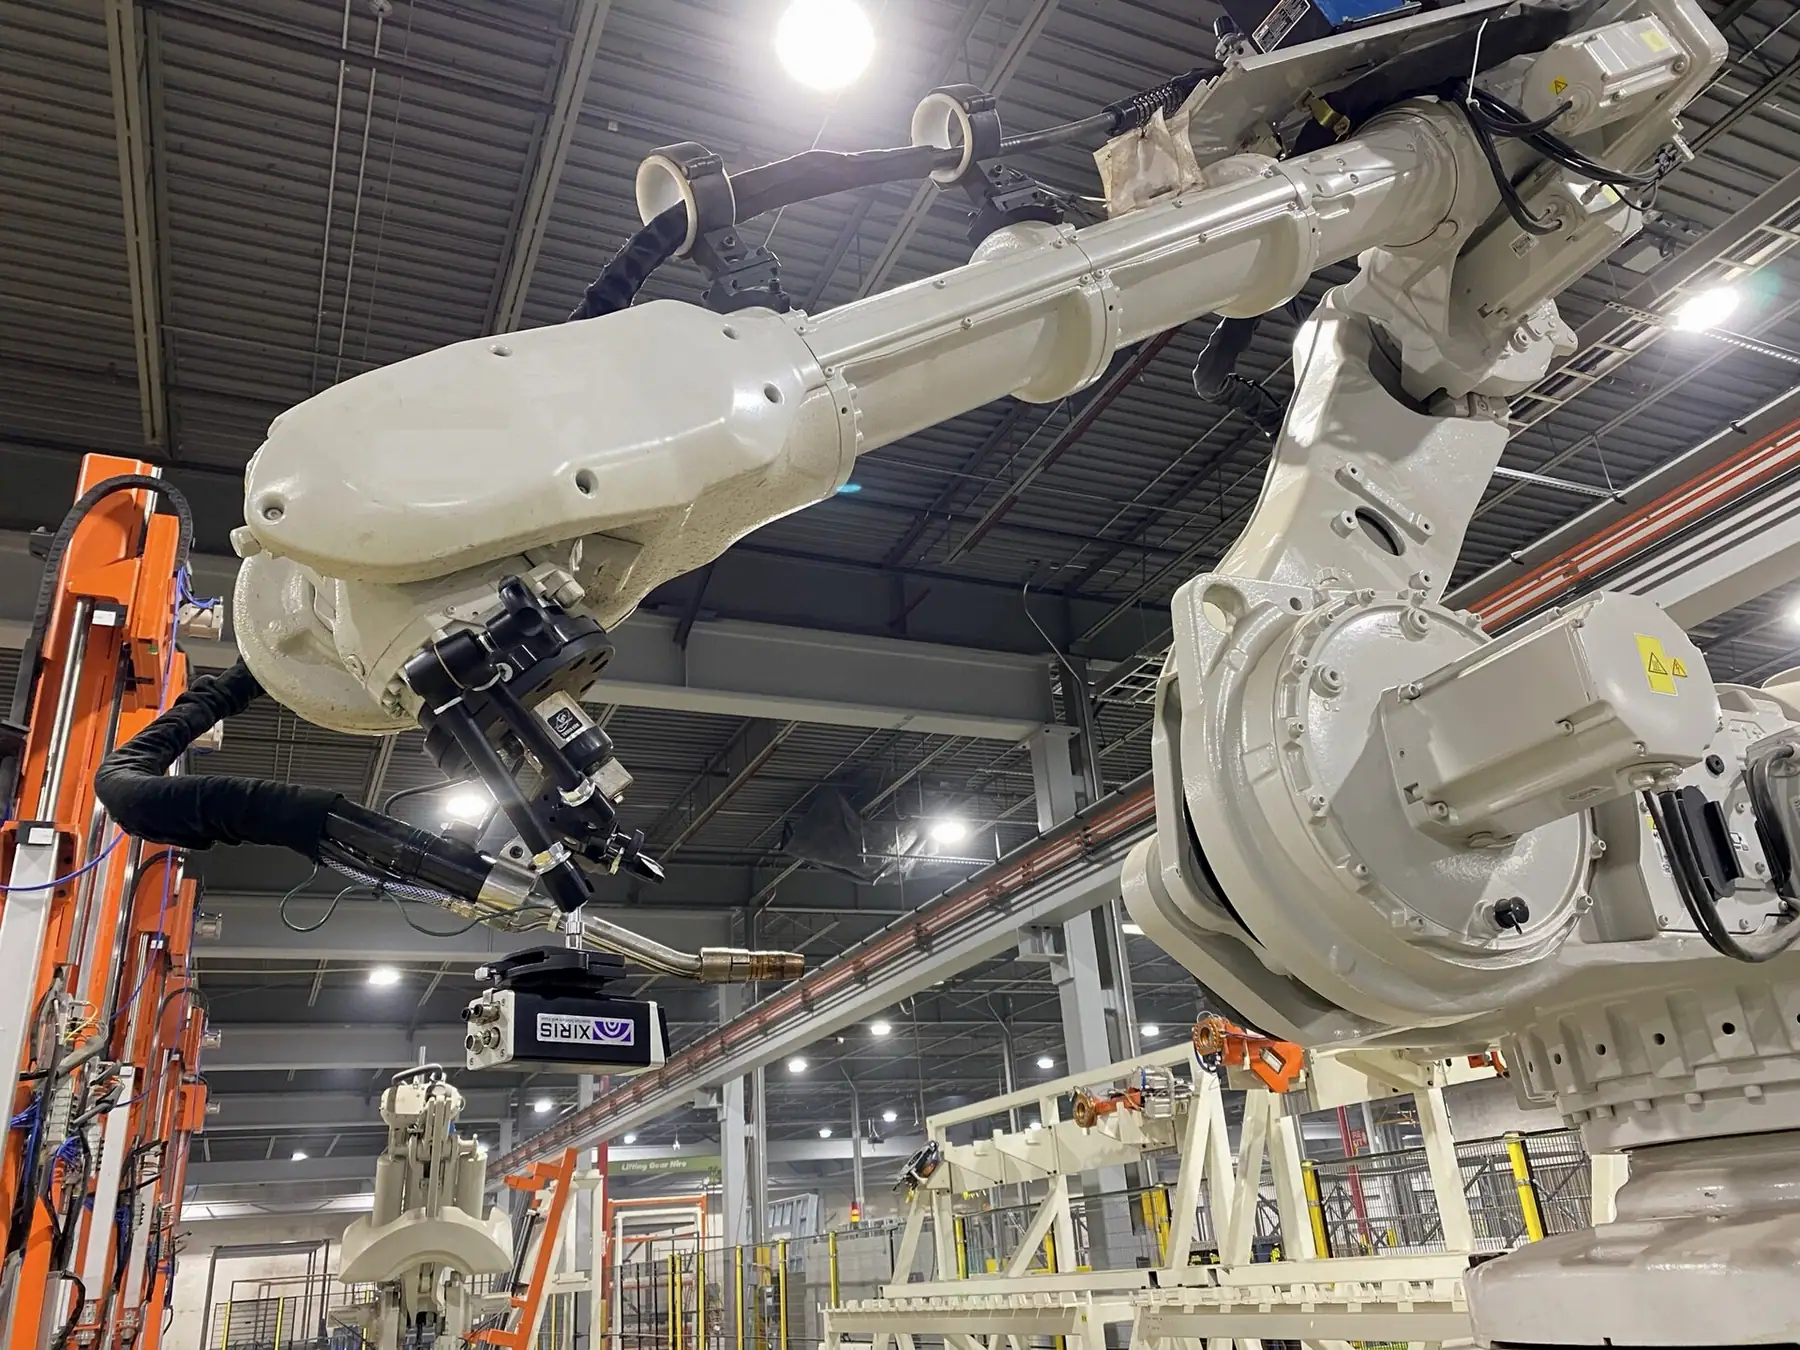
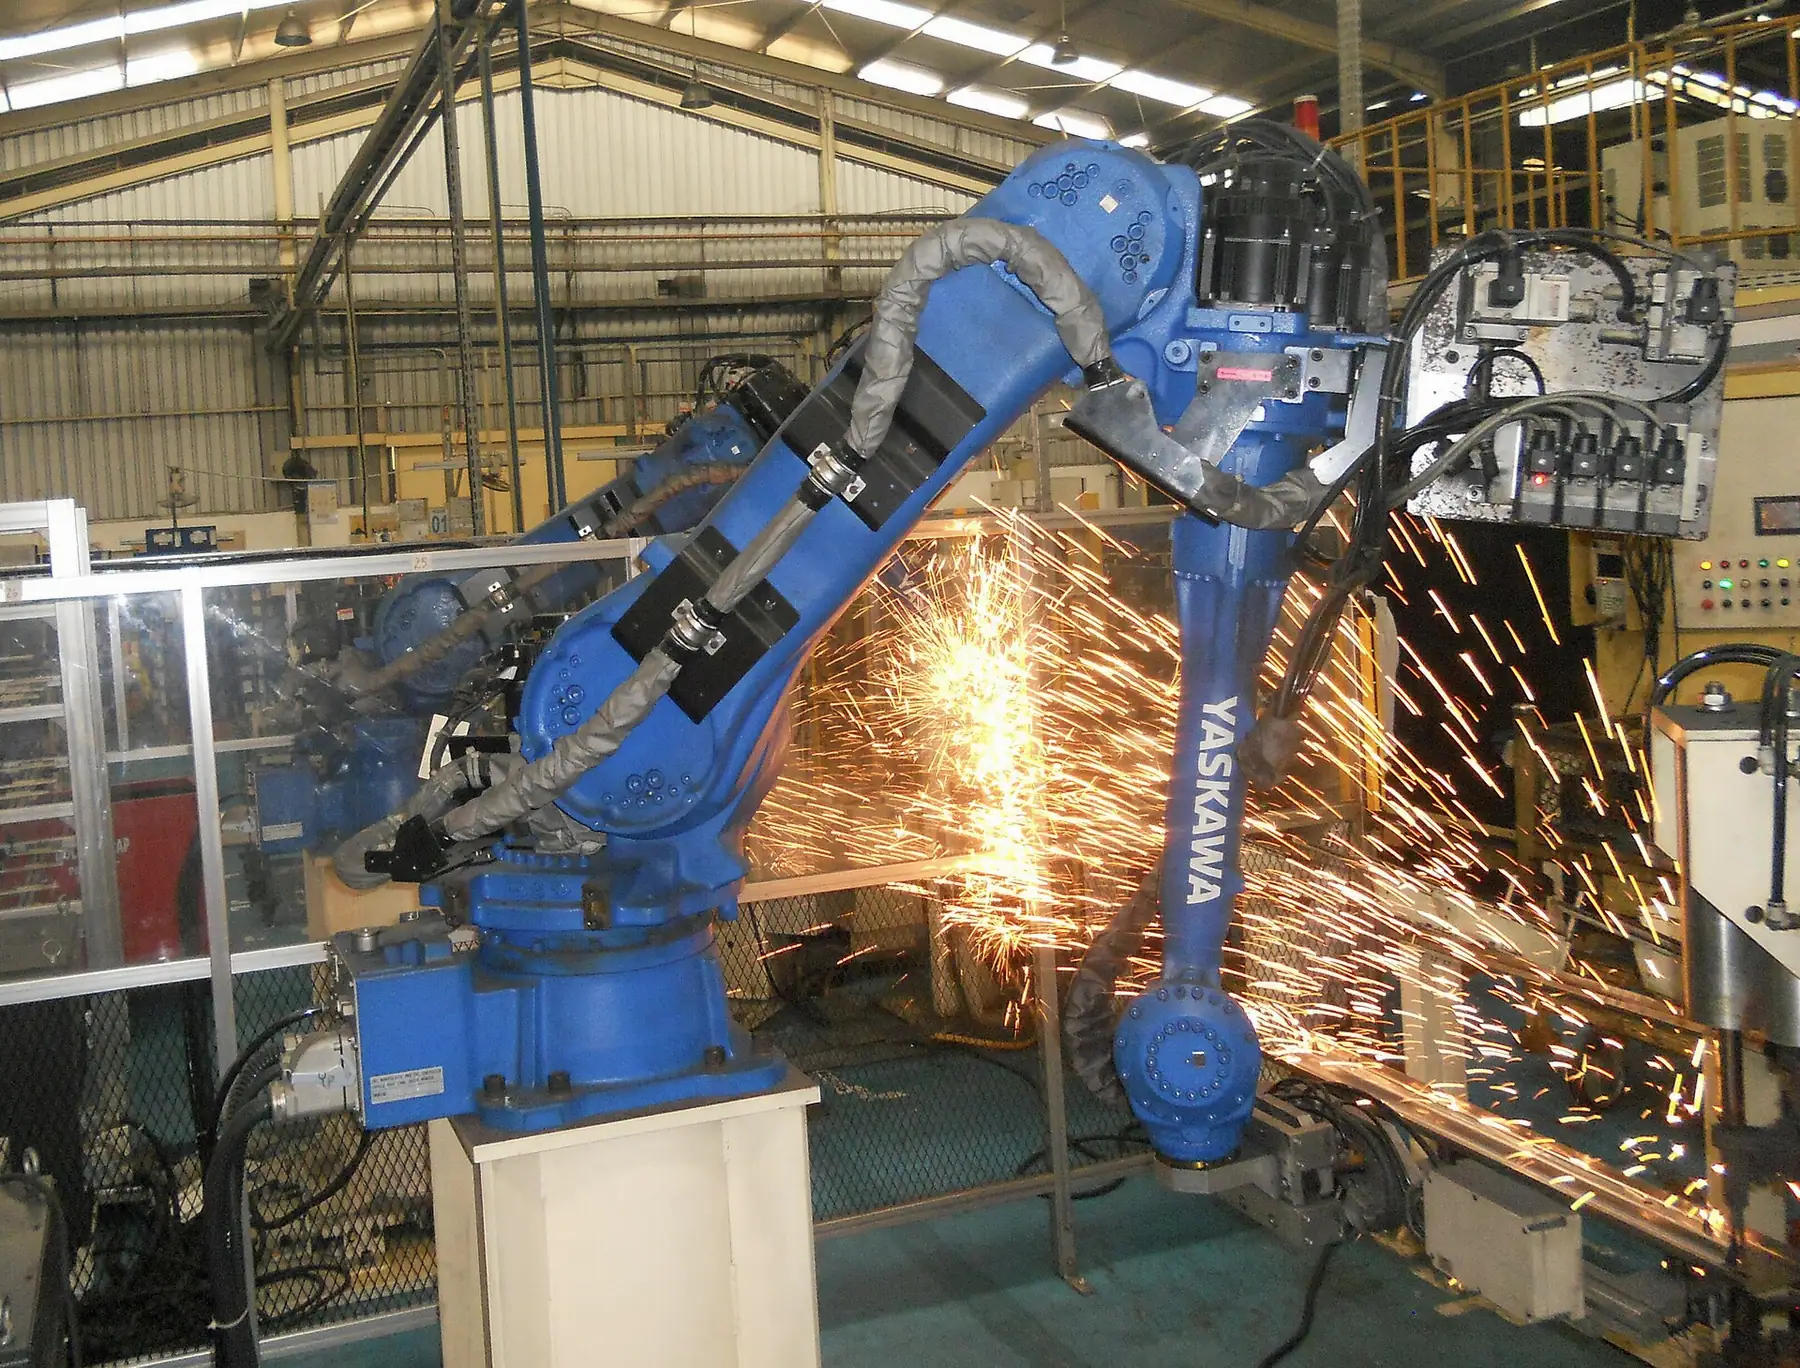
A robot cell succeeds less because of the robot itself than because of its gripper, fixture, reach and cycle design. We work with industry-standard robot platforms.
Approach
- Reach, collision and cycle-time simulation
- Product-specific gripper (EOAT) and fixture design
- Robot–PLC communication and cell management
- Risk assessment for collaborative applications
T-04 · VISION
Machine Vision
Machine vision tells robots where a part is and removes defective products from the line. A robust application depends as much on lighting and mechanical mounting as on the camera.
Approach
- Part localisation and robot guidance
- Presence / absence, orientation and assembly verification
- Code reading and traceability
- Lighting and field-of-view design
T-05 · SAFETY
Safety
Safety is not a fence added afterwards but a design input that starts with the risk assessment. Guards are positioned so that they never get in the operator's way.
Approach
- Risk assessment and definition of safety functions
- Circuit design with safety relays / safety PLCs
- Light curtains, area scanners and interlocked doors
- Safe speed and safe stop functions
T-06 · MECHANICAL ENGINEERING
Mechanical Engineering
Precision starts with a rigid frame and correctly toleranced parts. We design mechanics with manufacturability and ease of maintenance built in.
Approach
- 3D design and manufacturing drawings
- Strength and stiffness checks
- Tolerance stack-up and assembly sequence analysis
- Selection of standard, readily available components
Contact
Let's work with your existing platform standard.
Tell us which control and robot platforms your plant uses, and we'll build the system on that standard.